How to Deploy and Commission a Campus Delivery Robot
A reliable campus robot deployment combines workflow definition, site review, route mapping, hand-off design, building integration where required, real-condition testing, staff training and clear operating ownership.
Start with one real campus workflow
Document what moves, who loads it, where it goes, who receives it and what happens when a mission cannot complete.
The robot configuration should follow this operating procedure.
Review buildings and route continuity
Survey corridors, thresholds, lifts, doors, outdoor transitions, charging and normal pedestrian traffic.
A route that works after hours may behave differently during class changes or busy campus periods.
Map missions and configure approved interfaces
Create approved routes, destinations, schedules and any verified lift, door, access or notification integrations.
Each integration should have an owner, test method and fallback.
Test normal and exception journeys
Acceptance should cover loading, navigation, pedestrian traffic, destination arrival, hand-off, charging and recovery from failed missions.
The goal is to prove the complete campus logistics workflow, not only autonomous driving.
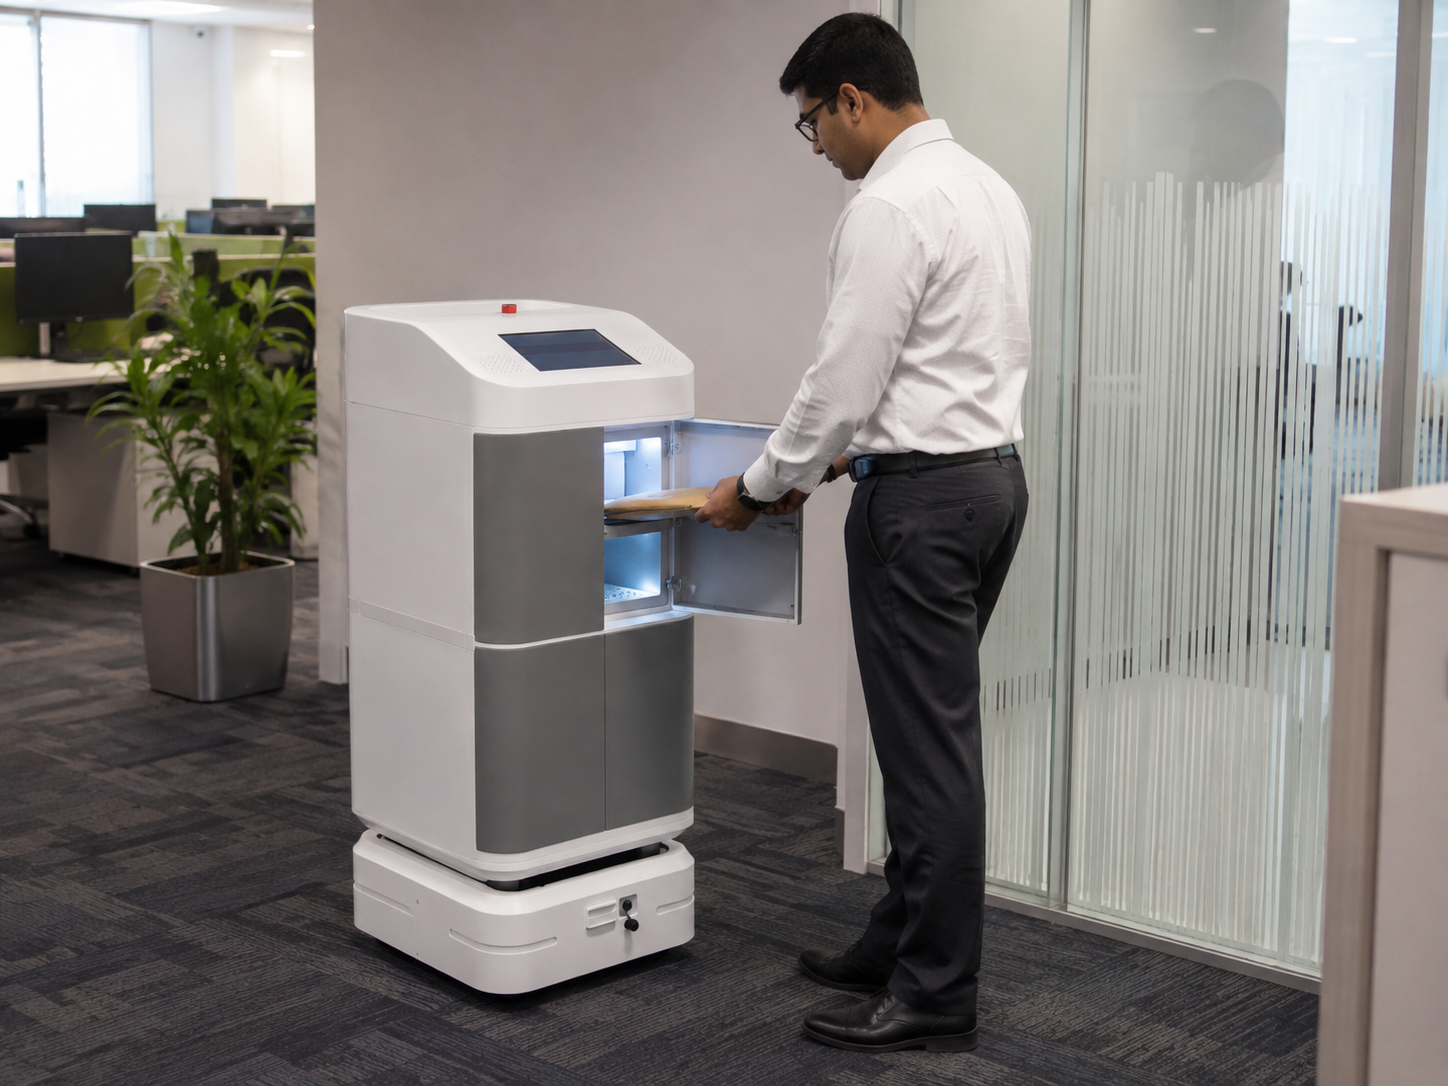
Train staff and control route changes
Define daily checks, mission ownership, escalation, maintenance and how route or building changes are revalidated.
Long-term reliability depends on disciplined operating ownership.
Frequently asked questions
How long does campus robot deployment take?
Timing depends on route complexity, buildings, floors, integrations, approvals and acceptance requirements and should be confirmed in the project plan.
What should acceptance testing include?
Test the complete mission including loading, route travel, lift or access steps where applicable, hand-off, exceptions and charging.
Do campus staff need training?
Yes. Relevant staff should understand loading, mission initiation, hand-off, exceptions, charging and support escalation.