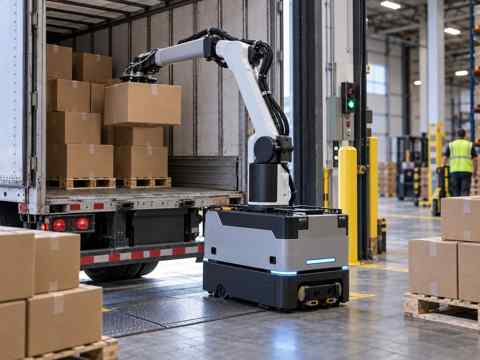
RECEIVING
Cargo Unloading Robot
Selected truck, container and dock-side carton unloading workflows.
Use cargo unloading, autonomous inventory scanning and mobile manipulation around clearly defined warehouse and manufacturing workflows.
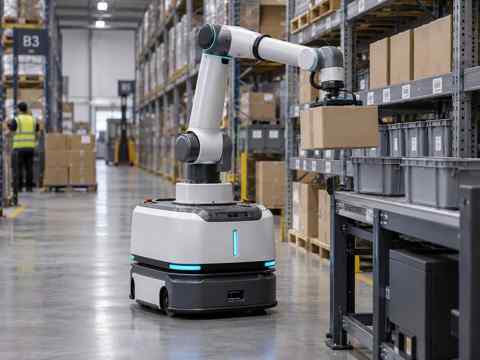
The right robot depends on the material, presentation, route, workpoint and system interface. RIFE structures each industrial deployment around the real process.
Use the dedicated robot configuration for each task.
Selected truck, container and dock-side carton unloading workflows.
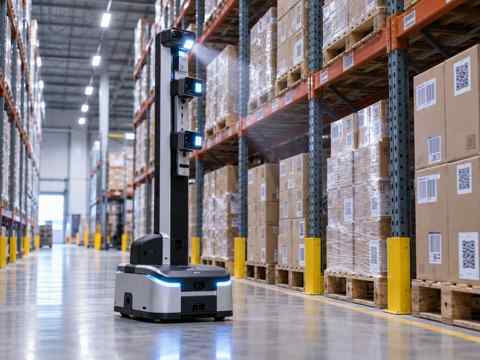
Autonomous aisle scanning for selected inventory visibility and inspection workflows.
Selected carton, bin, tote, picking and workstation handling workflows.
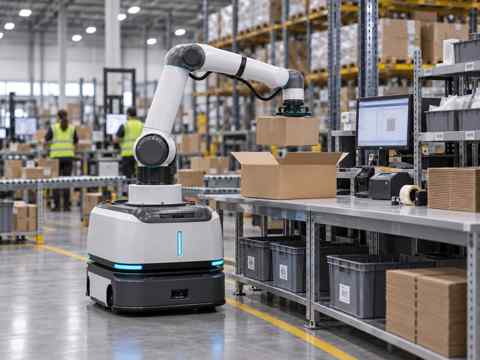
Project-configured AMR-style internal movement can be evaluated for suitable warehouse flows.
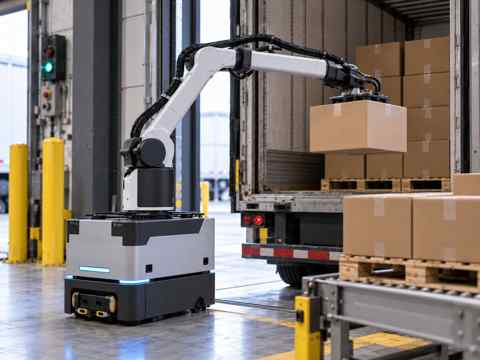
Cargo unloading projects are reviewed against vehicle, dock, package presentation and downstream hand-off.
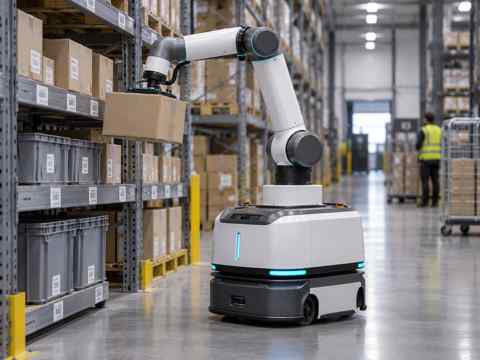
Mobile manipulation can support selected picking, packing, tote and workstation-transfer tasks after material and safety validation.
Select the unloading, scanning, picking or movement bottleneck.
Review material, geometry, routes and workpoints.
Select robot, handling and required interfaces.
Validate workflow, safety boundaries and hand-offs.
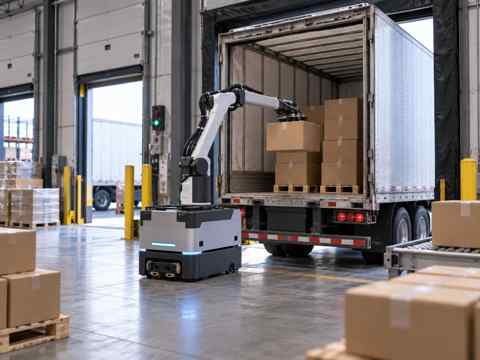
Selected cargo unloading and staging workflows.
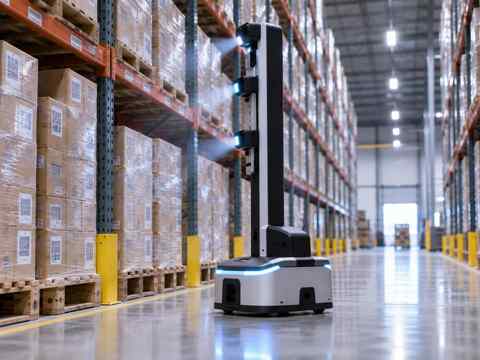
Autonomous scanning and inspection missions.
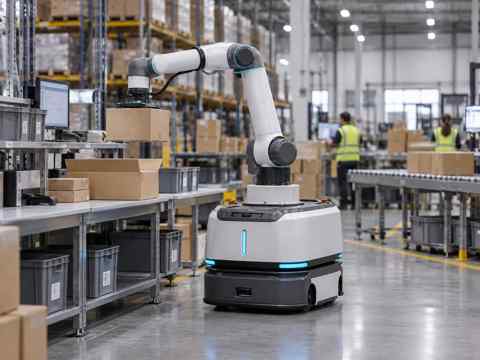
Selected carton, bin and tote handling.
Defined movements between shelves, staging and compatible workpoints.
Payload, reach, dimensions, sensors, battery, navigation, end-effector, safety and software interfaces are confirmed for the approved project.
The established family includes the Cargo Unloading Robot, Inventory Scanning Robot and Mobile Manipulator Robot.
Selected truck, container and dock workflows can be evaluated after reviewing cargo and site conditions.
It is positioned for project-configured autonomous aisle scanning and inventory visibility workflows.
Selected cartons, bins or totes can be considered after validating material and pickup geometry.
Share material, process, workpoints, routes and system constraints.