INBOUND LOGISTICS
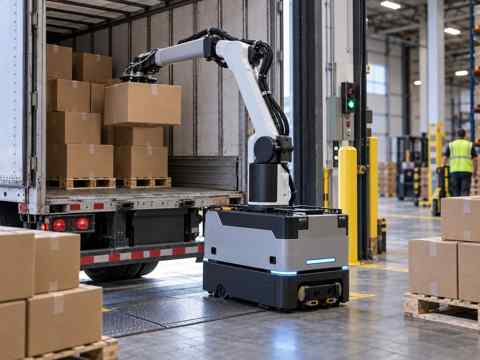
RIFE Cargo Unloading Robot
Mobile manipulation for selected truck, container and dock-side carton unloading and transfer workflows.
Build warehouse automation around the actual job: unload cartons, scan inventory, pick and handle approved materials, or move loads through project-configured workflows.
RIFE warehouse automation starts with the physical workflow: what arrives, what must be scanned or handled, where it needs to move and how operators and systems interact with it. The robot configuration follows that study.
Use the dedicated robot page for detailed application planning and project configuration.
Mobile manipulation for selected truck, container and dock-side carton unloading and transfer workflows.
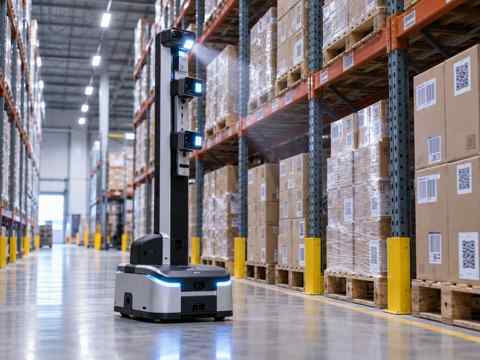
Autonomous aisle scanning for project-configured inventory visibility and warehouse inspection workflows.
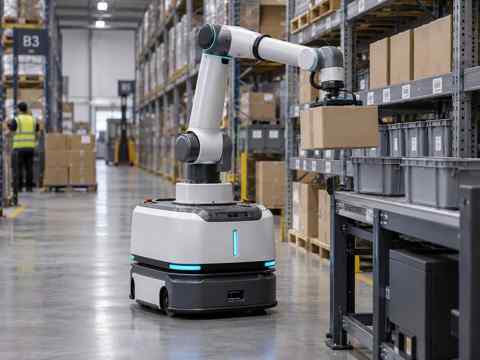
Mobile robotic handling for selected cartons, bins, totes, picking, packing and workstation transfers.
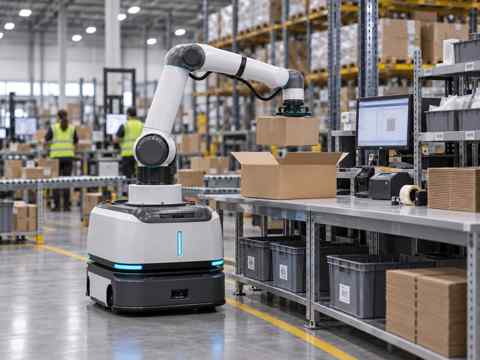
Project-configured autonomous material movement can be evaluated for suitable cartons, bins, totes and internal transfer workflows.
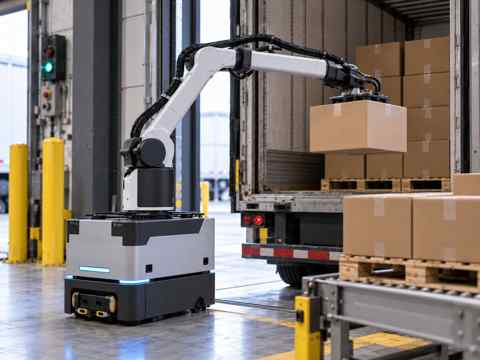
Cargo unloading projects are structured around the actual vehicle, dock, package presentation, handling method and downstream hand-off.
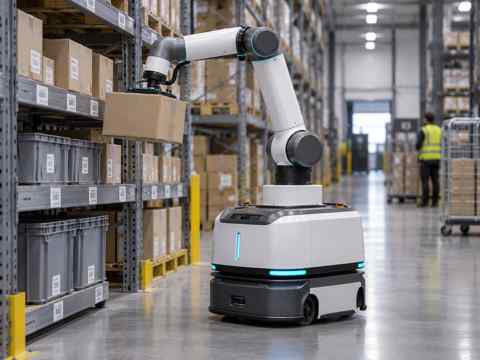
The mobile manipulator combines movement with project-selected robotic handling for suitable picking, tote, packing and workstation tasks.
Choose the unloading, scanning, picking or movement bottleneck to automate.
Review material, dimensions, presentation, routes, workpoints and operating constraints.
Select the robot, handling method, navigation and required project interfaces.
Validate the approved workflow, safety boundaries and hand-off points on site.
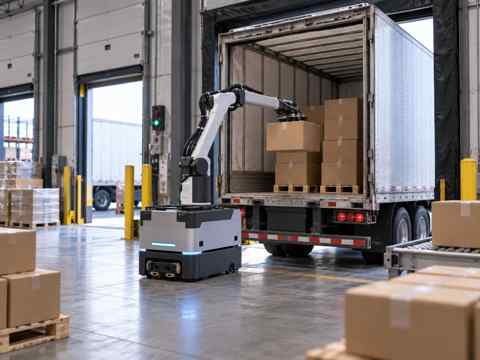
Selected cargo unloading and inbound carton transfer workflows.
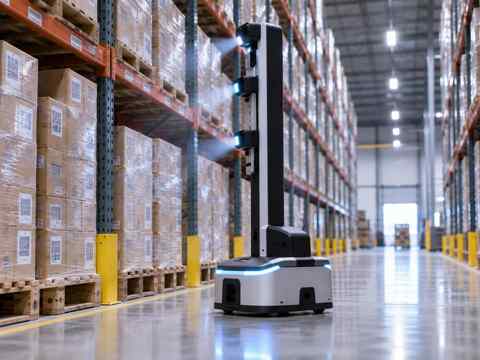
Autonomous scanning and project-configured inventory inspection missions.
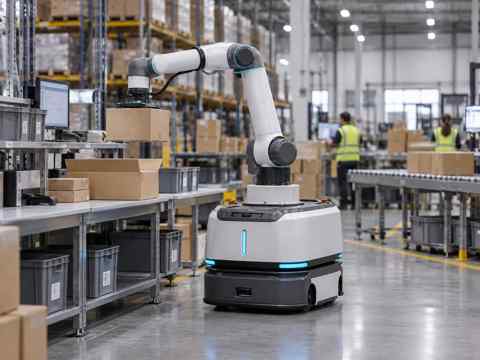
Selected carton, bin and tote handling using mobile manipulation.
Defined material movements between compatible shelves, staging points and workstations.
Payload, reach, dimensions, sensors, battery, navigation, end-effector, safety controls and software interfaces are confirmed for the selected robot and approved warehouse project.
The current warehouse family includes the RIFE Cargo Unloading Robot, RIFE Inventory Scanning Robot and RIFE Mobile Manipulator Robot, with additional project-configured AMR material-movement applications evaluated where suitable.
Selected unloading workflows can be evaluated after reviewing the cargo, vehicle or container geometry, dock conditions, handling method and downstream destination.
The RIFE Inventory Scanning Robot is positioned for project-configured autonomous aisle scanning and inventory visibility workflows. The final sensing and system configuration is selected for the project.
Selected cartons, bins and totes can be considered after validating their size and weight range, presentation, gripping method and pickup and drop geometry.
Selected integrations can be reviewed and are confirmed only after technical assessment and agreement of the project scope.
Share the material, current process, pickup and drop points, warehouse layout and required system interfaces. RIFE Robotics will review the workflow before confirming the robot configuration.