PICKING
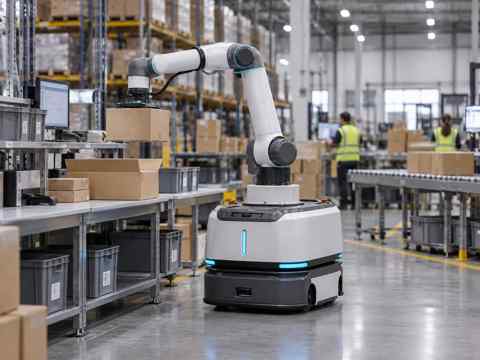
Carton Picking
Support selected repetitive carton-picking tasks where presentation, gripping and handling conditions suit the approved configuration.
RIFE Mobile Manipulator Robot combines mobile positioning with project-selected robotic manipulation for warehouse picking, carton or tote handling, workstation transfers and repetitive material-handling workflows. Final reach, payload, end-effector and integration are confirmed for each project.
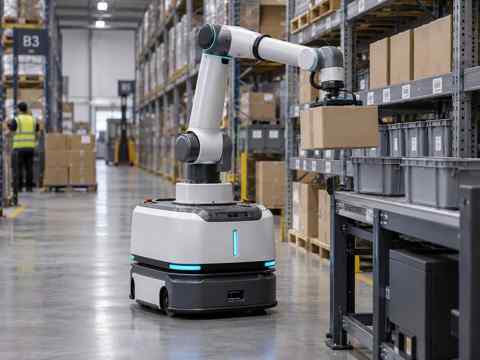
RIFE configures the mobile manipulator around the actual material, pickup and drop positions, operating route, end-effector and workcell constraints instead of assuming one fixed specification.
Each project is validated against the real material, pickup geometry, route, workpoints and safety requirements.
Support selected repetitive carton-picking tasks where presentation, gripping and handling conditions suit the approved configuration.
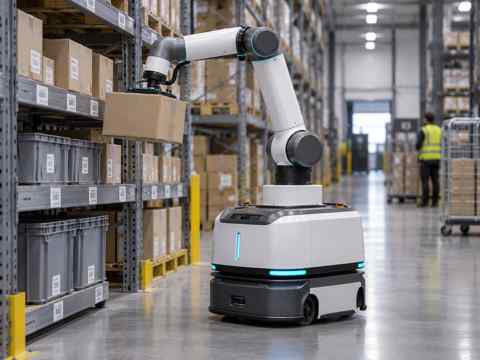
Move approved bins or totes between defined shelf, staging and workstation positions.
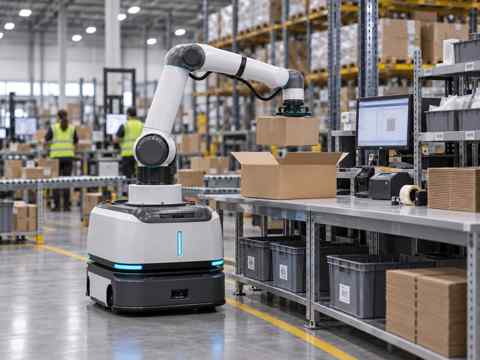
Bring robotic handling to selected packing or processing workpoints for repetitive material presentation and transfer.
Support defined material movements between compatible shelf locations and warehouse workstations.
A mobile platform and project-selected robotic arm can be commissioned around mapped routes and approved handling positions.
The configuration can support selected packing, kitting, replenishment or compatible workcell transfers after technical and safety review.
Review material type, size range, presentation and required handling outcome.
Select and validate the project-appropriate manipulation and end-effector concept.
Define approved travel paths, pickup positions and drop or workstation locations.
Commission the approved workflow with site-specific integration and safety controls.
Support approved repetitive picking tasks in suitable warehouse zones.
Present or transfer selected items around compatible packing workflows.
Support defined material movements for selected kitting and replenishment processes.
Move approved material between compatible warehouse or production workpoints.
Exact payload, reach, end-effector, mobile platform, battery, navigation, interfaces and safety controls are project-specific and confirmed after technical review.
It combines a mobile robotic platform with a manipulation system so selected handling tasks can be performed at multiple approved workpoints.
Handling depends on the item, size and weight range, presentation and selected end-effector; these are validated for each project.
Selected cartons, bins or totes can be considered when their handling conditions suit the approved project configuration.
Selected integrations can be evaluated and are subject to technical review and the approved project scope.
Machine tending is considered only for selected compatible workcells after technical and safety review.
Share the material, size and weight range, pickup and drop points, cycle or workflow, and any WMS or workcell constraints. RIFE Robotics will review the application before confirming the configuration.