REQUESTS
Mission Intake
Receive approved service or delivery requests.
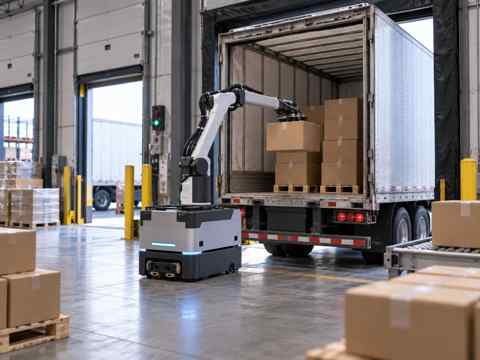
Fleet orchestration turns individual robots into a managed service with mission intake, priorities, availability, charging and exception handling.
Fleet orchestration turns individual robots into a managed service with mission intake, priorities, availability, charging and exception handling.
These areas become explicit design and acceptance items rather than assumptions.
Receive approved service or delivery requests.
Assign work according to availability and configured service rules.
Track fleet state and coordinate charging around the service model.
Surface blocked, failed or delayed missions for follow-up.
The fleet layer should show who can request work, what takes priority and how unavailable robots affect service.
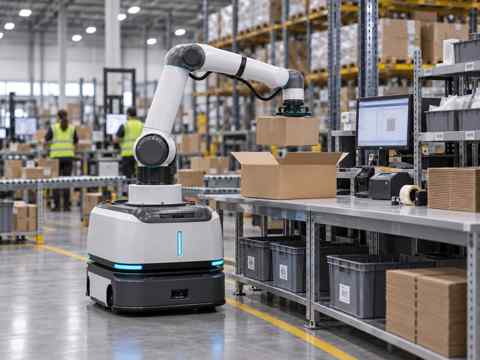
Autonomous service becomes reliable when failures have a visible state, owner and recovery process.
Approved user/system submits a mission.
Fleet layer selects available robot per rules.
Robot runs the mission and reports state.
Exceptions are surfaced to the responsible operator.
Receive approved service or delivery requests.
Assign work according to availability and configured service rules.
Track fleet state and coordinate charging around the service model.
Surface blocked, failed or delayed missions for follow-up.
The final technical specification is tied to the selected platform, site and interface owners.
Multi-robot management depends on the selected fleet platform and should be confirmed in the project scope.
Priority rules are configured around the operating workflow and service-level requirements.
The operating model should define reassignment, delay notification and manual fallback behavior.
Yes when an approved interface is available and the integration is included in scope.
Share the operating environment, current systems, users, constraints and the workflow you want to improve. RIFE can structure the appropriate technical review and deployment path.