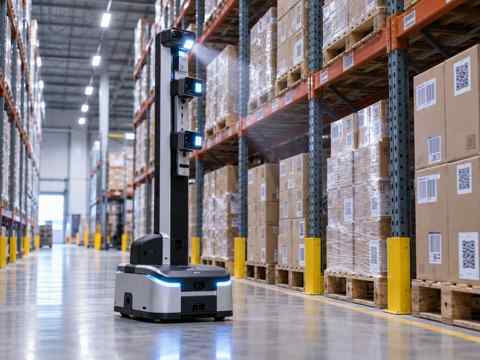
MAP
Site Mapping
Create and validate the robot-operable representation of the site.
Reliable navigation combines a validated map, localization, route constraints, obstacle handling, recovery behavior and controlled changes to the environment.
Reliable navigation combines a validated map, localization, route constraints, obstacle handling, recovery behavior and controlled changes to the environment.
These areas become explicit design and acceptance items rather than assumptions.
Create and validate the robot-operable representation of the site.
Maintain robot position relative to the commissioned map.
Define permitted paths, destinations and route constraints.
Specify behavior around people, movable objects and temporary blockages.
Routes, restricted zones, destinations, charging and recovery rules should be documented and change-controlled.
LiDAR, cameras, depth sensors and other perception hardware vary by robot. The project should state the actual platform rather than assume a universal stack.
Inspect routes, surfaces, traffic and obstacles.
Create and validate the operating map.
Set destinations, zones and recovery rules.
Run normal and blocked-route scenarios in the real site.
Create and validate the robot-operable representation of the site.
Maintain robot position relative to the commissioned map.
Define permitted paths, destinations and route constraints.
Specify behavior around people, movable objects and temporary blockages.
The final technical specification is tied to the selected platform, site and interface owners.
The exact mapping and sensor stack depends on the selected robot platform and should be stated in the project specification.
Obstacle handling is verified against the selected platform and real site conditions during commissioning.
Temporary obstacles should be handled according to the platform’s verified behavior; significant layout changes may require route or map updates.
Suitability depends on surfaces, gradients, clearances, traffic, lighting, connectivity and the selected platform.
Share the operating environment, current systems, users, constraints and the workflow you want to improve. RIFE can structure the appropriate technical review and deployment path.