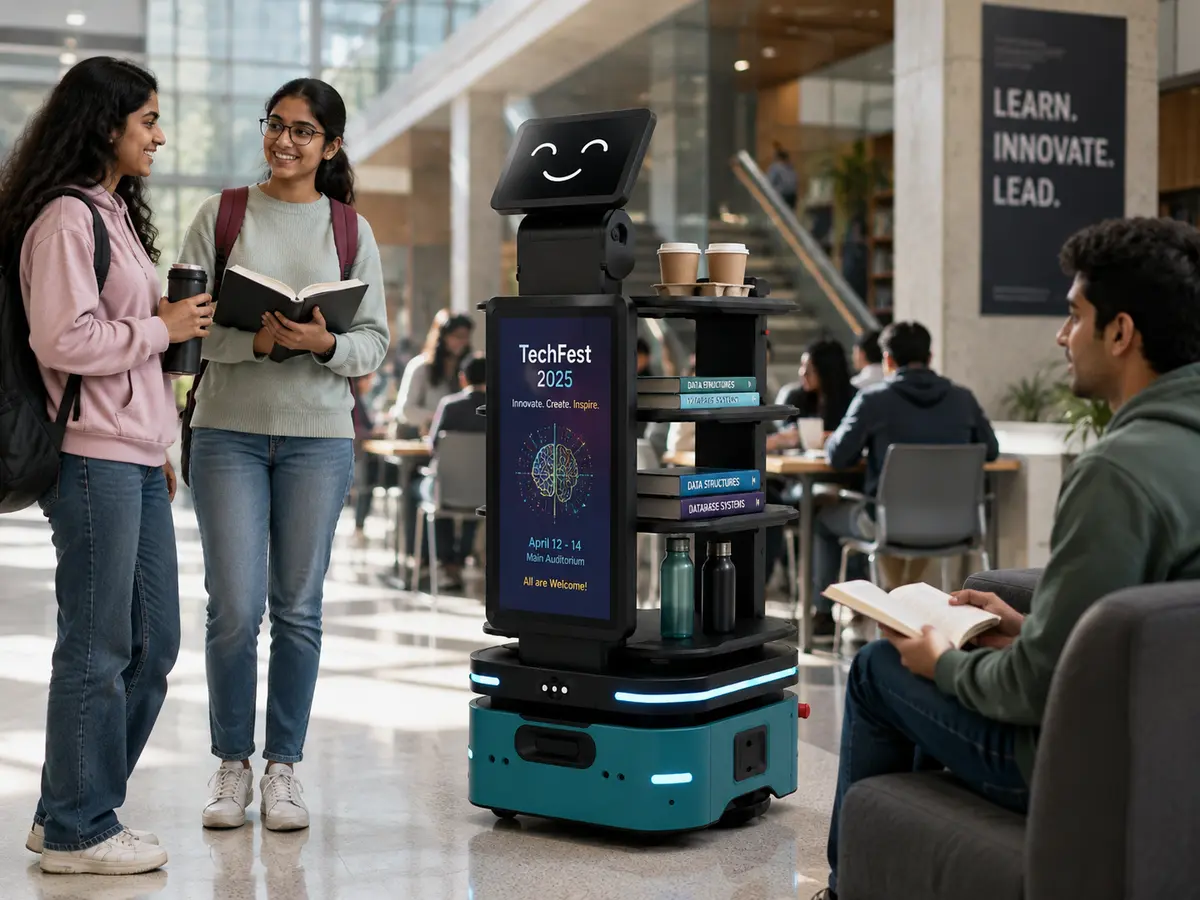
DEPARTMENTS
Department Delivery
Move approved documents and supplies between mapped departments.
Support selected documents, supplies and service-item journeys across mapped university buildings and approved campus routes.
Support selected documents, supplies and service-item journeys across mapped university buildings and approved campus routes.
Use the robot only where the route, payload, hand-off and operating environment are clearly defined.
Move approved documents and supplies between mapped departments.
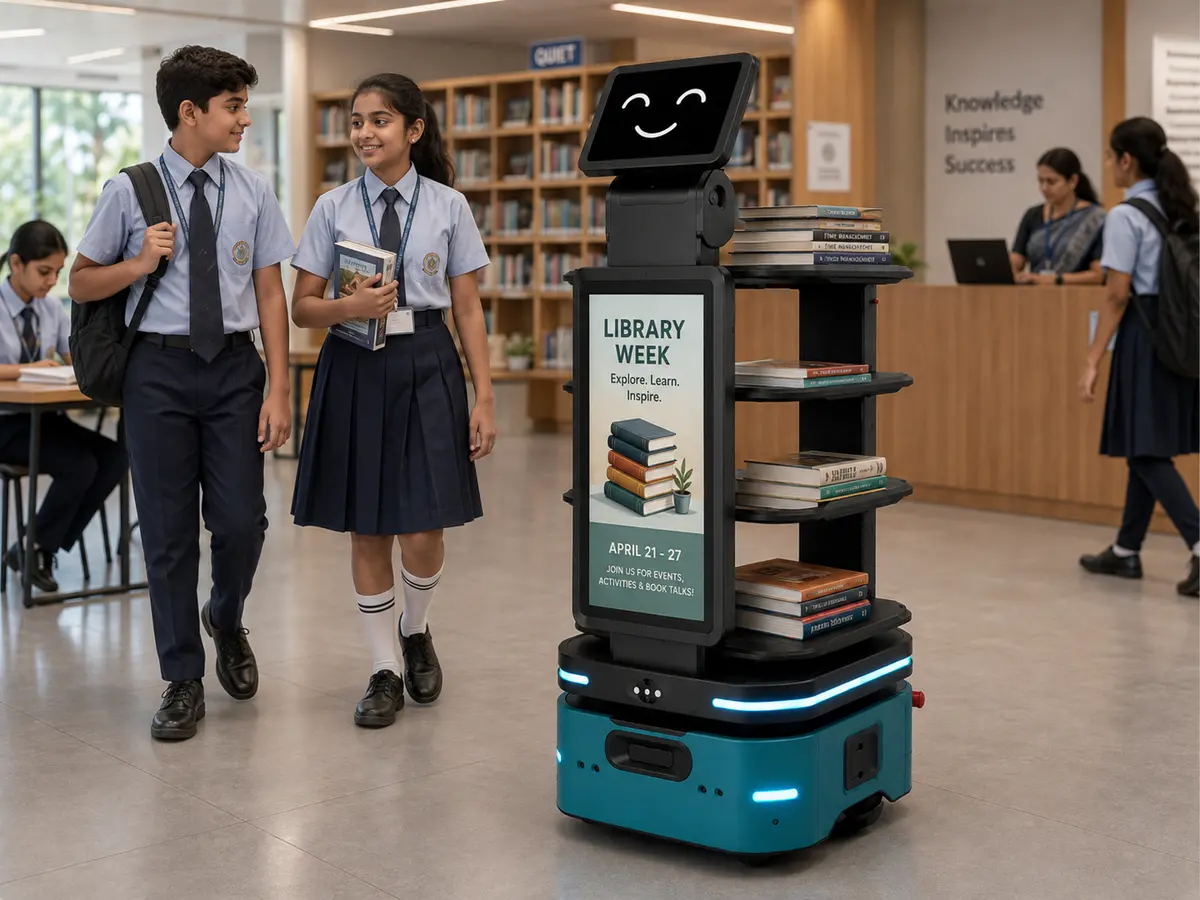
Selected books and learning materials between approved points.
Support repeatable document and service-item journeys.
Selected indoor service journeys in suitable buildings.
The robot configuration is selected around the application, payload, route, destination and hand-off process rather than a generic one-size-fits-all setup.
Universities often span multiple buildings and floors, so deployment is planned around connected operating areas, indoor routes and defined hand-off points.
Select campus delivery workflows.
Review buildings, floors and routes.
Select robot and hand-off method.
Commission approved campus missions.
Department-to-department internal movement.
Books and learning materials.
Documents and approved supplies.
Selected service-item journeys.
Dimensions, payload, battery profile, navigation, end-effector, authentication, software interfaces and building integrations are not assumed. They are confirmed for the selected model and approved project scope.
Selected indoor campus workflows can be configured where routes, buildings and hand-off points are suitable.
Yes, mapped department-to-department routes can be configured.
Selected book and learning-material workflows can be included.
That depends on route continuity, access and the approved site configuration.
Share the site, payload, route, pickup and destination points, operating hours and any required system interfaces. RIFE Robotics will review the workflow before confirming the configuration.