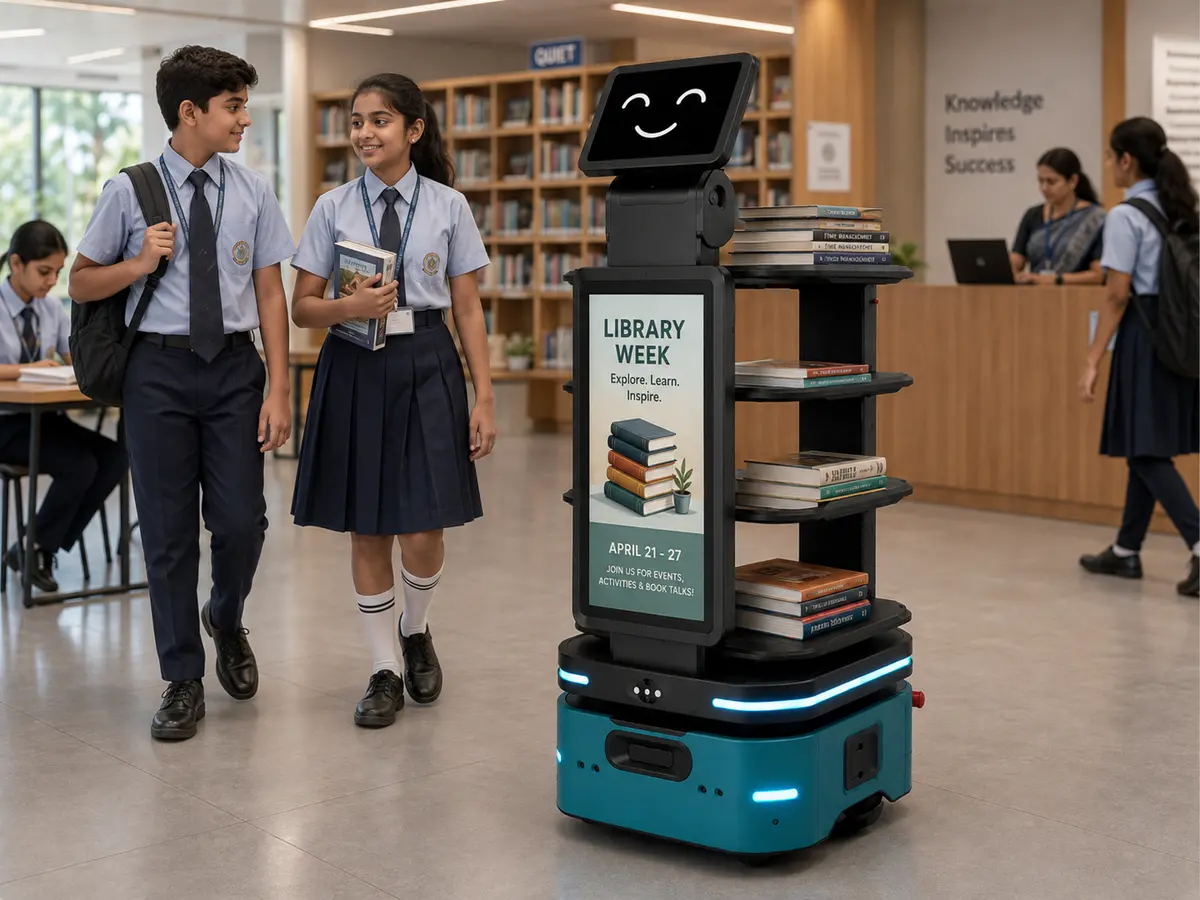
BOOKS
Book Movement
Move selected books between service points.
Support selected book, document and learning-material journeys between mapped library and school service points.
Support selected book, document and learning-material journeys between mapped library and school service points.
Use the robot only where the route, payload, hand-off and operating environment are clearly defined.
Move selected books between service points.
Support selected paperwork and learning-material runs.
Repeatable movement between circulation and mapped destinations.
Selected learning materials between approved points.
The robot configuration is selected around the application, payload, route, destination and hand-off process rather than a generic one-size-fits-all setup.
Book and material movement works best when pickup points, return desks, departments and delivery destinations are clearly mapped.
Choose books or materials to move.
Set pickup and destination points.
Select open or enclosed delivery format.
Commission approved library routes.
Selected book and material pickup.
Mapped internal destinations.
Selected repeatable movement of approved items.
Selected internal school or library logistics.
Dimensions, payload, battery profile, navigation, end-effector, authentication, software interfaces and building integrations are not assumed. They are confirmed for the selected model and approved project scope.
Selected book-movement workflows can be configured between mapped pickup and destination points.
Selected internal material-delivery workflows can be considered for suitable school environments.
Approved document and learning-material workflows can be configured.
The appropriate Premium or enclosed delivery format is selected after reviewing the payload and hand-off process.
Share the site, payload, route, pickup and destination points, operating hours and any required system interfaces. RIFE Robotics will review the workflow before confirming the configuration.